Success case
EdgeAI2Wild: Integrate BlueROV-2 with NVIDIA Jetson for An Affordable Under-ice Sensing ROV.
Due to climate change, the Arctic is warming two-to-four times faster than the rest of
- Industry
- Environment & Sustainability
- Region
- 阿拉斯加·野外测试
- Application
- Under-ice research sampling
Project background and needs
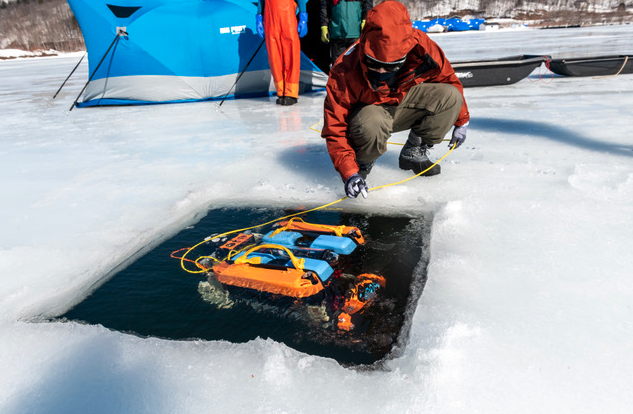
A University of Rhode Island team modified the BlueROV-2 into an under-ice sensing platform and conducted field tests in Utqiagvik, Alaska, to collect biogeochemical data at the ice-water boundary.
Lack of under-ice research tools
- Biogeochemical research in ice-covered areas is limited by the lack of robust under-ice sensing techniques.
- Most AUVs were originally developed for open-water applications.
Needs to validate a portable under-ice sensing platform.
Base platform localization
- The base BlueROV model lacks the sensors needed for good localization.
- The project needed to connect add-on sensors into the control and visualization systems.
Needs to integrate localization and sensing data.
Solution and architecture
Underwater platform
BlueROV-2 integrates an acoustic modem, a USBL device, AHRS/DVL odometry, and dissolved oxygen and chlorophyll sensors.
Computing and topside
A Jetson mini PC connects the sensors via ROS; the topside computer runs the BlueROV control interface and a customized RViz display for sensor measurements.
Solution components
On-site gallery (2)
Discuss your application with our team
Tell us about your requirements and deployment environment.