Success case
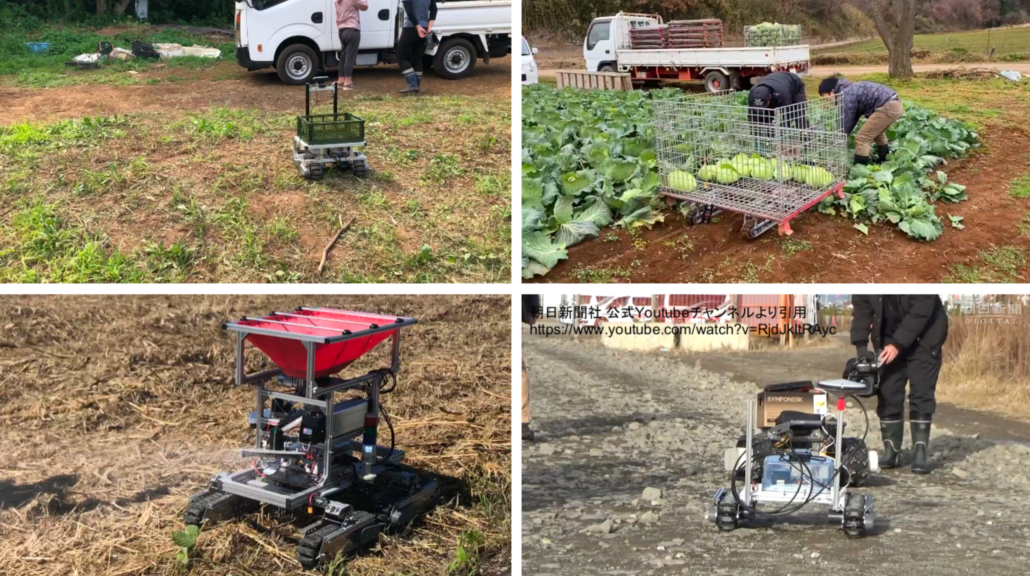
Rough Terrain Robot with Computer Vision for Harsh Environment Mapping and Heavy Transportation
Hardware: reComputer J4012 with Jetson Orin NX 16GB module Use Case Provider: CuboRex Application: Rough
- Industry
- Agriculture
- Region
- 日本·田间机器人
- Application
- Off-Road Tracked Robot
Project background and needs
CuboRex's tracked farm robot in Japan uses Jetson Orin NX for edge vision processing, targeting complex-terrain work such as fields, construction sites, and disaster sites.
Heavy Loads and Terrain
- Uneven paths and steps made it harder for people to carry heavy loads.
- Handling such outdoor tasks manually was costly and time-consuming.
A mobility robot capable of handling uneven terrain was needed.
Robot Development Readiness
- AI/CV developers might lack robotics hardware expertise.
- Learning ROS from scratch required time to build the necessary knowledge.
The mobility platform needed to be integrated with development tools to support autonomous driving development.
Solution and architecture
Mobility and Sensing
The CuGo V3 tracked chassis combines RPLIDAR, GNSS, and an IMU to capture environmental, location, and motion data.
Edge Development
Jetson Orin NX runs Jetson Linux with ROS/ROS 2, enabling computer vision tools and customization of NavigationStack.
Solution components

Discuss your application with our team
Tell us about your requirements and deployment environment.